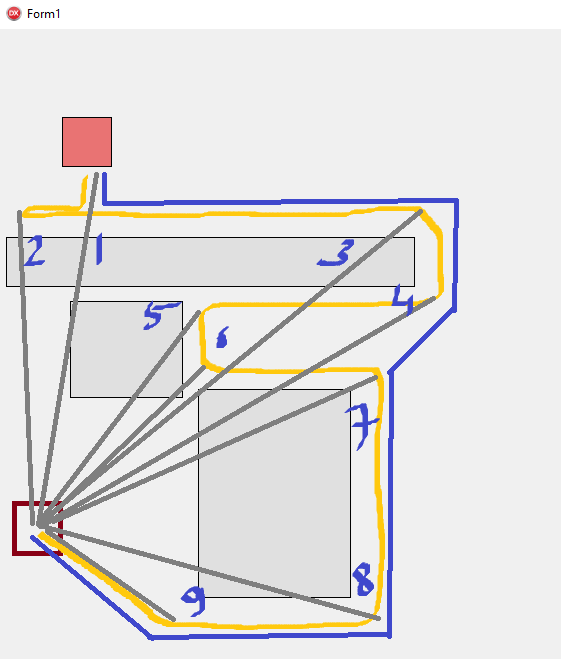
Güzel cevaplarınız için teşekkür ederim.
Yol bulma algoritmalarının çoğu @
engerex fikir yürüttüğünüz şekliyle çalışıyor. Benzer bir yapıyı aşağıya bırakıyorum. Biraz da olsa bir başarı sağladım.
@
mrmarman daha ilk adımı başarılı atamadığım için "ilk adımım doğru mu" sorusunu soramadım. Sorduğunuz sorulara sıra gelemedi

İhtiyaca göre şekillenecek bir başlangıç lazım dediğiniz gibi. Amacım sadece objeleri bir birine çarpmadan oradan oraya sürüklemek şimdilik.
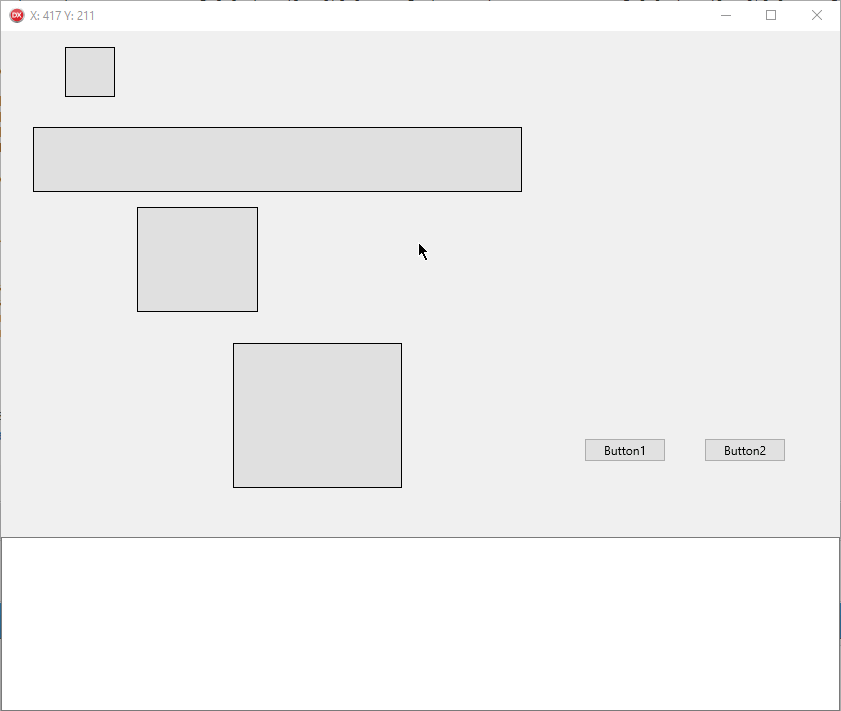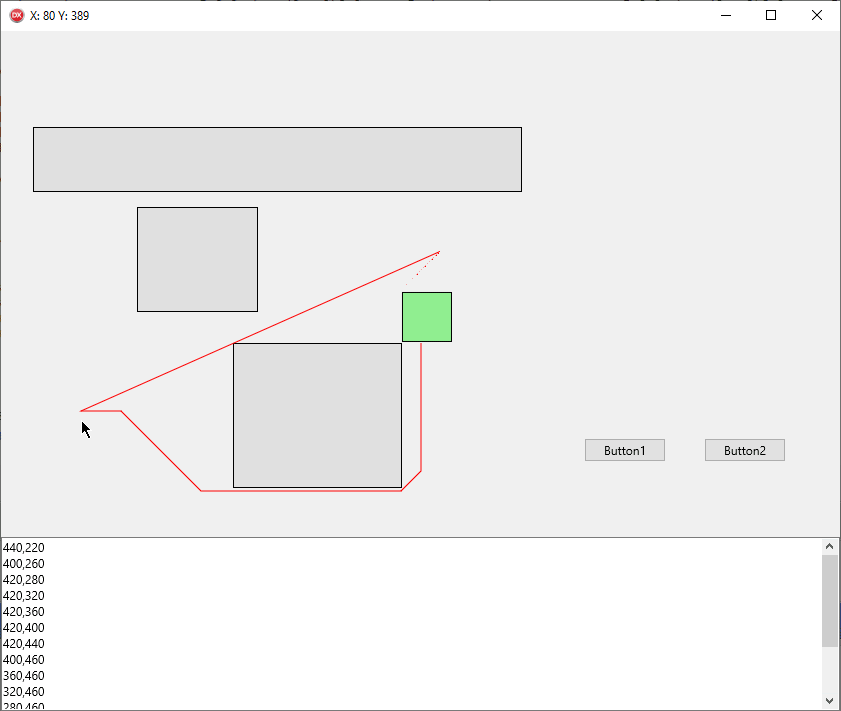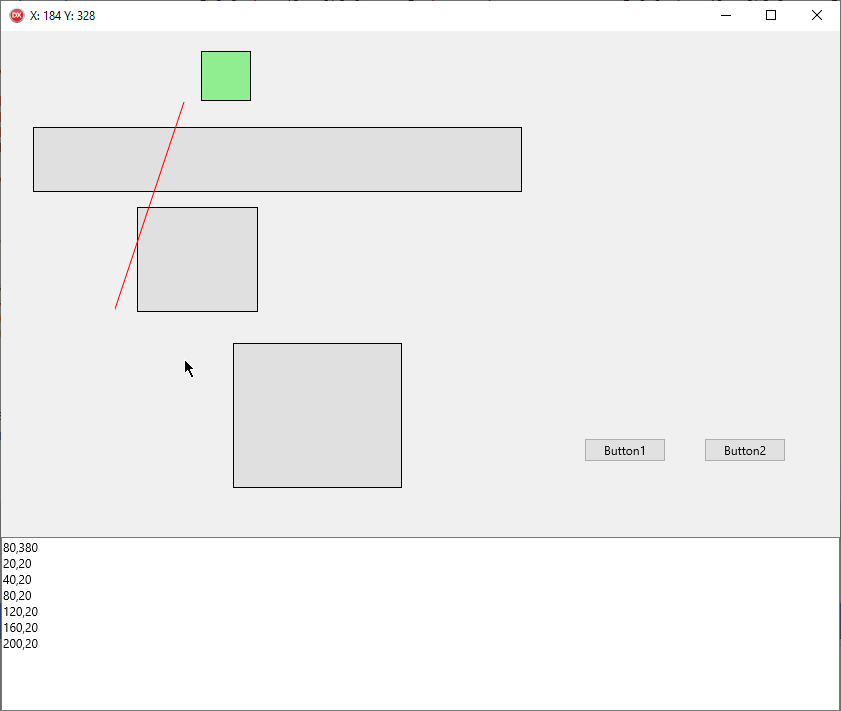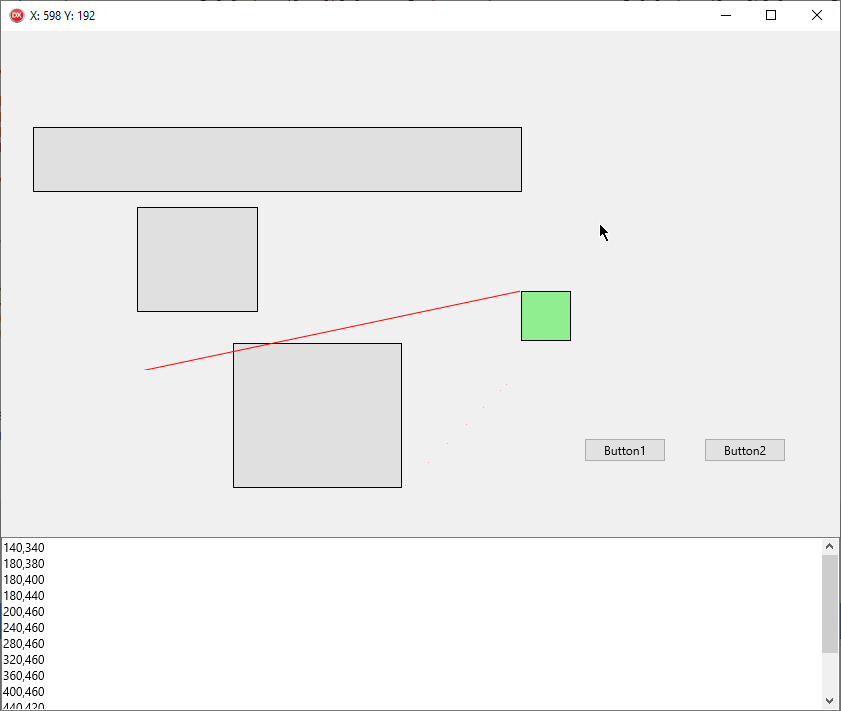
ChatGPT ile zar zor oluşturuldu
unit PathfindingUnit;

interface

uses
 System.SysUtils, System.Types, System.Generics.Collections, System.Classes, FMX.Objects, FMX.Graphics,
 System.UITypes;

type
 TNode = record
   X, Y: Integer;
   GCost, HCost, FCost: Integer;
   ParentX, ParentY: Integer;
   constructor Create(aX, aY: Integer);
 end;

 TPathfinding = class
 private
   FCharacter: TRectangle;
   FTarget: TPoint;
   FObstacles: TArray<TRectangle>;
   FPathList: TStringList;
   FGridSize: Integer;

   procedure OptimizePath;
   function GetValidNeighbors(CurrentNode: TNode): TArray<TNode>;
   function IsCollision: Boolean;
 public
   constructor Create(Character: TRectangle; Target: TPoint; Obstacles: TArray<TRectangle>; GridSize: Integer = 20);
   destructor Destroy; override;
   procedure FindPath;
   property PathList: TStringList read FPathList;      function IsWalkable(X, Y: Integer): Boolean;
 end;

implementation

{ TNode }

constructor TNode.Create(aX, aY: Integer);
begin
 X := aX;
 Y := aY;
 GCost := 0;
 HCost := 0;
 FCost := 0;
 ParentX := -1;
 ParentY := -1;
end;

{ TPathfinding }

constructor TPathfinding.Create(Character: TRectangle; Target: TPoint; Obstacles: TArray<TRectangle>; GridSize: Integer);
begin
 FCharacter := Character;
 FTarget := Target;
 FObstacles := Copy(Obstacles, 0, Length(Obstacles));
 FPathList := TStringList.Create;
 FGridSize := GridSize;
end;

destructor TPathfinding.Destroy;
begin
 FPathList.Free;
 inherited;
end;

function TPathfinding.GetValidNeighbors(CurrentNode: TNode): TArray<TNode>;
var
 Neighbors: TList<TNode>;
 dx, dy: Integer;
 Neighbor: TNode;
begin
 Neighbors := TList<TNode>.Create;
 try
   for dx := -1 to 1 do
     for dy := -1 to 1 do
     begin
       if (dx = 0) and (dy = 0) then
         Continue;
       // Diyagonal hareketi kontrol et, engellerin kenarlarından geçmemesini sağlar
       if (Abs(dx) + Abs(dy) = 2) and (not IsWalkable(CurrentNode.X + dx, CurrentNode.Y) or not IsWalkable(CurrentNode.X, CurrentNode.Y + dy)) then
         Continue;

       Neighbor := TNode.Create(CurrentNode.X + dx, CurrentNode.Y + dy);
       if IsWalkable(Neighbor.X * FGridSize, Neighbor.Y * FGridSize) then
         Neighbors.Add(Neighbor);
     end;
   Result := Neighbors.ToArray;
 finally
   Neighbors.Free;
 end;
end;

function GetMinFCostNode(OpenList: TDictionary<Integer, TNode>): TNode;
var
 Node: TNode;
 MinNode: TNode;
 MinCost: Integer;
begin
 MinCost := MaxInt;
 for Node in OpenList.Values do
 begin
   if Node.FCost < MinCost then
   begin
     MinCost := Node.FCost;
     MinNode := Node;
   end;
 end;
 Result := MinNode;
end;


function CheckBoundryCollision( R1, R2 : TRect; pR : PRect = nil; OffSetY : LongInt = 0; OffSetX : LongInt = 0): boolean;
begin
 if( pR <> nil ) then
  begin
   with( R1 ) do
    R1:=Rect( Left+OffSetX, Top+OffSetY, Right-(OffSetX * 2), Bottom-(OffSetY * 2));
   with( R2 ) do
    R2:=Rect( Left+OffSetX, Top+OffSetY, Right-(OffSetX * 2), Bottom-(OffSetY * 2));

   Result:=IntersectRect( pR^, R1, R2 );
  end
 else begin
       Result:=( NOT ((R1.Bottom - (OffSetY * 2) < R2.Top + OffSetY)
         or(R1.Top + OffSetY > R2.Bottom - (OffSetY * 2))
          or( R1.Right - (OffSetX * 2) < R2.Left + OffSetX)
           or( R1.Left + OffSetX > R2.Right - (OffSetX * 2))));
      end;
end;

procedure TPathfinding.FindPath;
var
 StartNode, EndNode: TNode;
 OpenList, ClosedList: TDictionary<Integer, TNode>;
 CurrentNode, Neighbor: TNode;
 GCost, HCost, FCost: Integer;
 PathFound: Boolean;

 function CalculateHCost(Node1, Node2: TNode): Integer;
 begin
   Result := Abs(Node1.X - Node2.X) + Abs(Node1.Y - Node2.Y);  // Manhattan mesafesi
 end;
begin

 if IsCollision = True then
 begin
   FCharacter.Fill.Color := TAlphaColorRec.Red;
   Exit;
 end;

 FCharacter.Fill.Color := TAlphaColorRec.Lightgreen;
 StartNode := TNode.Create(Round(FCharacter.Position.X / FGridSize), Round(FCharacter.Position.Y / FGridSize));
 EndNode := TNode.Create(Round(FTarget.X / FGridSize), Round(FTarget.Y / FGridSize));

 OpenList := TDictionary<Integer, TNode>.Create;
 ClosedList := TDictionary<Integer, TNode>.Create;
 PathFound := False;
 try
   OpenList.Add(StartNode.X * 10000 + StartNode.Y, StartNode);

   while OpenList.Count > 0 do
   begin
     CurrentNode := GetMinFCostNode(OpenList);

     OpenList.Remove(CurrentNode.X * 10000 + CurrentNode.Y);
     ClosedList.Add(CurrentNode.X * 10000 + CurrentNode.Y, CurrentNode);

     // Hedefe ulaşıldıysa yolu oluştur
     if (CurrentNode.X = EndNode.X) and (CurrentNode.Y = EndNode.Y) then
     begin
       PathFound := True;
       while (CurrentNode.ParentX <> -1) and (CurrentNode.ParentY <> -1) do
       begin
         FPathList.Add(Format('%d,%d', [CurrentNode.X * FGridSize, CurrentNode.Y * FGridSize]));
         CurrentNode := ClosedList[CurrentNode.ParentX * 10000 + CurrentNode.ParentY];
       end;
       FPathList.Add(Format('%d,%d', [StartNode.X * FGridSize, StartNode.Y * FGridSize]));
       OptimizePath;
       Break;
     end;

     // Geçerli düğümün komşularını incele
     for Neighbor in GetValidNeighbors(CurrentNode) do
     begin
       // Çarpışmayı kontrol et
       if ClosedList.ContainsKey(Neighbor.X * 10000 + Neighbor.Y) or not IsWalkable(Neighbor.X * FGridSize, Neighbor.Y * FGridSize) then
         Continue;

       GCost := CurrentNode.GCost + 1;
       HCost := CalculateHCost(Neighbor, EndNode);
       FCost := GCost + HCost;

       var TempNeighbor := Neighbor;
       if not OpenList.ContainsKey(TempNeighbor.X * 10000 + TempNeighbor.Y) then
       begin
         TempNeighbor.GCost := GCost;
         TempNeighbor.HCost := HCost;
         TempNeighbor.FCost := FCost;
         TempNeighbor.ParentX := CurrentNode.X;
         TempNeighbor.ParentY := CurrentNode.Y;
         OpenList.Add(TempNeighbor.X * 10000 + TempNeighbor.Y, TempNeighbor);
       end;
     end;
   end;

   // Eğer yol bulunamadıysa uyarı göster
   if not PathFound then
     FCharacter.Fill.Color := TAlphaColorRec.Red;
 finally
   OpenList.Free;
   ClosedList.Free;
 end;
end;

function TPathfinding.IsCollision: Boolean;
var
 tmpRect: TRectangle;
begin
 Result := False;
 tmpRect := TRectangle.Create(nil);
 tmpRect.Height :=  FCharacter.Height;
 tmpRect.Width  :=  FCharacter.Width;
 tmpRect.Position.X := FTarget.X;
 tmpRect.Position.Y := FTarget.Y;

 for var Obstacle in FObstacles do
 begin
   if CheckBoundryCollision(tmpRect.BoundsRect.Round,Obstacle.BoundsRect.Round) = True then
   begin
     Result := True;
     Break;
   end;
 end;

 FreeAndNil(tmpRect);
end;

function TPathfinding.IsWalkable(X, Y: Integer): Boolean;
var
 CharRect, ObstacleRect: TRectF;
begin
 CharRect := TRectF.Create(X, Y, X + FCharacter.Width, Y + FCharacter.Height);
 Result := True;

 for var Obstacle in FObstacles do
 begin
   ObstacleRect := TRectF.Create(Obstacle.Position.X, Obstacle.Position.Y, Obstacle.Position.X + Obstacle.Width, Obstacle.Position.Y + Obstacle.Height);
   if CharRect.IntersectsWith(ObstacleRect) then
   begin
     Result := False;
     Break;
   end;
 end;
end;

procedure TPathfinding.OptimizePath;
var
 i: Integer;
 CurrDir, NextDir: TPoint;
begin
 i := 0;
 while i < FPathList.Count - 2 do
 begin
   var Point1 := TPoint.Create(StrToInt(FPathList[i].Split([','])[0]), StrToInt(FPathList[i].Split([','])[1]));
   var Point2 := TPoint.Create(StrToInt(FPathList[i + 1].Split([','])[0]), StrToInt(FPathList[i + 1].Split([','])[1]));
   var Point3 := TPoint.Create(StrToInt(FPathList[i + 2].Split([','])[0]), StrToInt(FPathList[i + 2].Split([','])[1]));

   CurrDir := Point2 - Point1;
   NextDir := Point3 - Point2;

   if (CurrDir.X = NextDir.X) and (CurrDir.Y = NextDir.Y) then
     FPathList.Delete(i + 1)
   else
     Inc(i);
 end;
end;

end.
Kendimce kullanımı;
procedure TForm1.Layout1MouseDown(Sender: TObject; Button: TMouseButton;
 Shift: TShiftState; X, Y: Single);
var
 Pathfinding: TPathfinding;
 Obstacles: TArray<TRectangle>;
 i: integer;
 pdata: TPathData;
begin
 // Engelleri diziye ekleyin
 pa.Stop;
 SetLength(Obstacles, 3);
 Obstacles[0] := Rectangle4;
 Obstacles[1] := Rectangle2;
 Obstacles[2] := Rectangle3;
 memo1.Lines.Clear;
 Layout1.Repaint;
 Application.ProcessMessages;

 Pathfinding := TPathfinding.Create(Character, Point(Round(X), Round(Y)), Obstacles);
 try

   Pathfinding.FindPath;

   //for var i := 0 to Pathfinding.PathList.Count - 1 do
   for i := Pathfinding.PathList.Count - 1 downto 0 do
     Memo1.Lines.Add(Pathfinding.PathList[i]); // Koordinatları gösterme
 finally
   Pathfinding.Free;
 end;

 pdata := TPathData.Create;
 for i := 0 to Memo1.Lines.Count-1 do
 begin
   if Memo1.Lines.Strings[i] <> '' then
   begin
     if i = 0 then pdata.MoveTo(PointF(Round(memo1.Lines.Strings[i].Split([','])[0].ToSingle),Round(memo1.Lines.Strings[i].Split([','])[1].ToSingle)));
     pdata.LineTo(PointF(Round(memo1.Lines.Strings[i].Split([','])[0].ToSingle),Round(memo1.Lines.Strings[i].Split([','])[1].ToSingle)));

   end;
 end;
 pdata.ClosePath;
 Layout1.Canvas.BeginScene;
 try
   Layout1.Canvas.Stroke.Color := TAlphaColorRec.Red;
   Layout1.Canvas.Stroke.Thickness := 1;
   Layout1.Canvas.Stroke.Dash := TStrokeDash.Solid;
   Layout1.Canvas.DrawPath(pdata,100);
 finally
   Layout1.Canvas.EndScene;
 end;

 pdata.Free;
 if Memo1.Lines.Count <= 0 then
   exit;
 ipath := 0;
 pa.StartValue.X := Character.Position.X;
 pa.StartValue.Y := Character.Position.Y;
 pa.StopValue.X := Character.Position.X;
 pa.StopValue.Y := Character.Position.Y;
 pa.Start;
end;
pa komponenti FGX eklenti seti içerisindeki PositionAnimation.
GitHub - theilgaz/FGX: This is a repacked FGX Components for Delphi 10.4 Sydney. This pack is compatible with Delphi 10.3 Rio and earlier versions.